Double-Sided Synchronizer
Mechanical two-way synchronizer.
blockType: Engee1DMechanical.Clutches.DoubleSidedSynchronizer
|
Path in the library: |
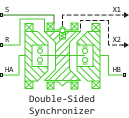
Description
Block Double-Sided Synchronizer It is a two-way synchronizer containing two coupled cam clutches, two coupled conical clutches and one lock for translational motion. Unlike conventional synchronizers, two-way synchronizers synchronize and engage gears on both the input and output shafts of the gearbox. Two-way synchronizers can simultaneously engage and disconnect gears on two shafts, which allows you to create more complex gear engagement schemes. Such synchronizers are widely used in heavy commercial vehicles, off-road vehicles, and some high-performance automotive transmissions.
Moving the gearshift lever in the negative direction causes the clutch ring to engage with the hub. . Moving the gearshift lever in the positive direction causes the clutch ring to engage with the hub . When the amount of displacement of the gear lever is less than the gap between the ring and the hub of the bevel clutch, the synchronizer is in the neutral position and does not transmit torque.
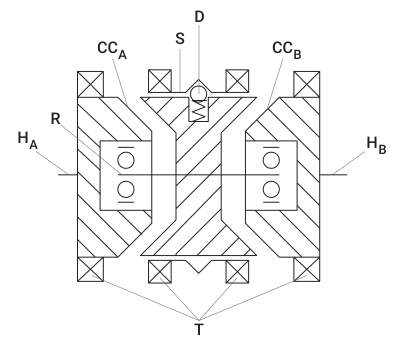
The diagram shows the two-way synchronizer turned off. In this state, the shafts of the ring ® and the hubs (HA and HB) can rotate independently at different speeds. As the gearshift lever (S) moves in the negative direction of the friction surface of the bevel clutch (CCA) touch and create a moment of friction, which reduces the difference in rotational speeds between the shafts of the ring and the hubs. The teeth of the cam clutch (T) can engage when the translational force acting on the gear lever exceeds the peak locking force (D). The peak locking force must provide sufficient time and normal force to equalize the rotational speeds of the ring shafts and hubs so that the cam clutch can engage. Similarly, moving the gearshift lever in the positive direction allows the friction surfaces of the conical clutch to come into contact. (CCB) and ensures that the ring shaft engages with the hub shaft (HB).
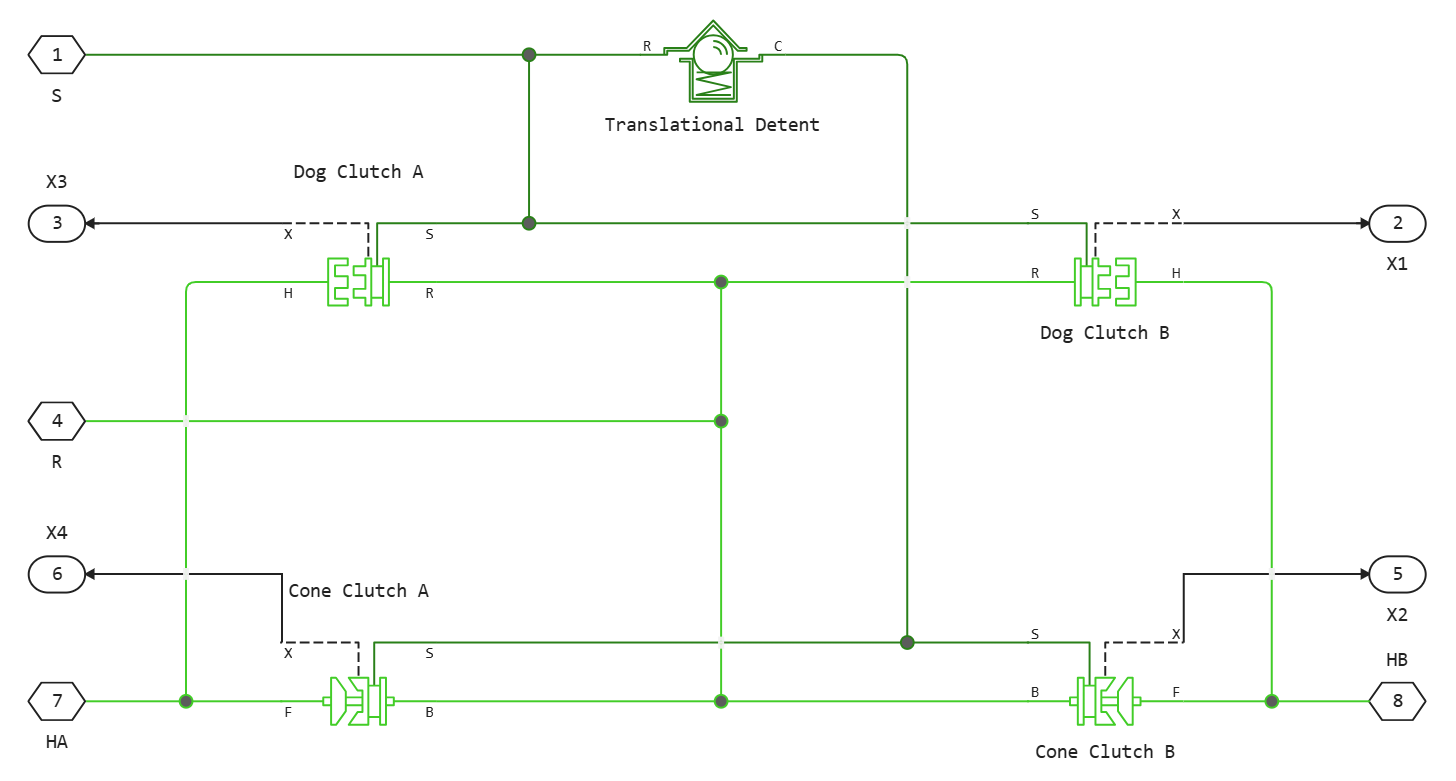
The model is implemented using two blocks Dog Clutch, two blocks Cone Clutch and one block Translational Detent.
The connections R, HA and HB are non—directional ports belonging to the domain of rotational mechanics, which are a ring ®, a hub (HA) and the hub (HB) respectively. The S connection is a non—directional port belonging to the domain of translational mechanics, which is a gearshift knob.
The connections X1 and X2 are output scalar signals that indicate the positions of the gearshift lever of the cam and bevel couplings, respectively. The tables below show the values of X1 and X2 in typical coupling cases.
| Condition of the cam clutch | X1 |
|---|---|
Turned off |
|
Fully engaged with the hub |
The negative sum of the gap between the ring and the hub and the cam height |
Fully engaged with the hub |
The positive sum of the gap between the ring and the hub and the cam height |
| Condition of the conical coupling | X2 |
|---|---|
Turned off |
|
Fully engaged with the hub |
The negative value of the gap between the ring and the hub |
Fully engaged with the hub |
The positive value of the gap between the ring and the hub |
The lever positions X1 and X2 correspond to zero when the synchronizer is fully open. When the cam clutch is fully engaged with the hub , the position X1 corresponds to the negative sum of the gap between the ring and the hub and the cam height. When the cam clutch is fully engaged with the hub , the position X1 corresponds to the positive sum of the gap between the ring and the hub and the cam height. When the conical coupling is fully engaged with the hub , position X2 corresponds to a negative clearance value between the ring and the hub. When the conical coupling is fully engaged with the hub , the position X2 corresponds to a positive clearance value between the ring and the hub.
Torque transmission models
You can choose one of the following models of torque transmission.
The approximate model of the friction clutch
If for the parameter Torque transmission model the value is set Friction clutch approximation - Suitable for HIL and linearization The block considers the inclusion of the clutch as a phenomenon of friction between the ring and the hub. This setting is better suited for linearization, fixed-step modeling, and hardware-software modeling. The block uses a composite implementation of the block Fundamental Friction Clutch.
When using this setting, the coupling has three possible configurations: off, on, and locked. In the off state, the contact force between the ring and the hub is zero. This force remains zero until the gearshift lever reaches the minimum position to engage the clutch.
When the cams of the ring and hub overlap exceeds the minimum value for switching on, the contact force between the two components begins to increase linearly with a change in the position of the gear lever .
When fully engaged, the contact force reaches its maximum value, and the coupling switches to a locked state. In this state, the ring and hub rotate as a single unit without slipping. To unlock the clutch, the transmitted torque must exceed the value of the parameter Maximum transmitted torque.
dynamic model with backlash
If for the parameter Torque transmission model the value is set Dynamic with backlash The block simulates phenomena such as backlash, torsional compliance, and contact forces between the ring and hub cams. This model provides higher accuracy than the approximate friction clutch model.
When using this setting, the coupling has two possible configurations: off and on. In the off state, the contact force between the ring and the hub is zero. This force remains zero until the gearshift lever reaches the minimum position to engage the clutch.
When the cams of the ring and hub overlap exceeds the threshold value for switching on, the clutch transmits the torque. This torque is the sum of the torques of the spring and the damper, including the gap between the cams of the ring and the hub, so that
where
-
— torsional stiffness of the coupling ring hub;
-
— the relative angle between the ring and the hub relative to the common axis of rotation;
-
— the gap between the cams of the ring and the hub;
-
— the relative angular velocity between the ring and the hub. This variable describes the rate of slippage of the two components relative to each other.
Malleable end stops limit the forward movement of the gearshift lever and the ring. The compliance model considers end stops as linear spring-damping systems. The position of the end stops depends on the relative angle and angular velocity between the cams of the ring and the hub:
-
If the cams are aligned and the relative angular velocity is less than the maximum value for turning on the clutch, then the stop position is determined by the sum of the gap between the ring and the hub when fully turned off and the cam height. The clutch can turn on in this stop position.
-
If the cams are not aligned or the relative angular velocity exceeds the maximum value for coupling activation, the stop position is set in such a way as to prevent the ring from engaging with the hub. The clutch does not turn on in this stop position.
Translational friction prevents the gearshift lever and the ring from moving. This friction is the sum of the Coulomb and viscous components, so that
where
-
— the total force of translational friction acting on the gearshift lever and the ring;
-
— coefficient of kinetic friction between the cams of the ring and the hub;
-
— vertically directed force between the cams of the ring and the hub;
-
— the speed of translational movement of the gearshift lever and the ring;
-
— the threshold value of the translational velocity; below this threshold value, the hyperbolic tangent function smooths the Coulomb friction force to zero when the speed of the gearshift lever and the ring tends to zero;
-
— the coefficient of viscous damping acting on the gearshift lever and the ring.
modal dynamic model
If for the parameter Torque transmission model the value is set Dynamic modal The block determines the discrete modal behavior of the clutch by reading the position of the gear lever from the non-directional mechanical port S. This setting takes into account the more complex dynamics of the clutch.
and it works faster than the settings. Friction clutch approximation - Suitable for HIL and linearization and Dynamic with backlash.
You can use the setting Dynamic modal to simulate clutch locking when the speed difference is too great for the clutch discs to trigger. The block represents the coupling lock as a spring-damping system in which the coefficients of elasticity and damping can be parameterized. The engagement modes overlap, which prevents them from changing until the position of the gear lever goes beyond the engagement overlap area. The area of overlap of the engagement is determined by the parameter Tooth overlap to engage.

Lever position limitations:
-
— position of the gearshift lever in port S;
-
— parameter value Tooth height;
-
— the value of the Ring hub clearance parameter when disengaged;
-
— parameter value Tooth overlap to engage;
-
— parameter value Engagement speed threshold.
Switching mode positions:
-
— the clutch is completely off;
-
— the clutch is switched off when the position of the gearshift lever is in the area defined by ; the coupling can switch from the off state to the on state if ;
-
— the clutch is turned on when located in the area defined by ; the coupling can switch from the on to the off state if ;
-
— the clutch is fully engaged;
-
— when located in the area of the engagement overlap, the clutch is activated only when the speed difference is less than the parameter value. .
Thermal modeling
It is possible to simulate the effects of heat flow and temperature changes using an additional non-directional heat port T. By default, this port is hidden. To use it, in the parameter group Cone Clutch set for the parameter Friction model meaning Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients. Then specify the appropriate thermal parameters for the component.
Linearization
To optimize the model for linearization, in the parameter group Dog Clutch use for the parameter Torque transmission model meaning Friction clutch approximation - Suitable for HIL and linearization.
Hardware and software modeling
For optimal simulation performance in the parameter group Dog Clutch use for the parameter Torque transmission model meaning Friction clutch approximation - Suitable for HIL and linearization.
Assumptions and limitations
The model does not take into account inertial effects. To account for inertia, you can add a block Inertia to each port of the synchronizer model.
Ports
Conserving
#
T
—
heat flow
warm
Details
A non-directional heat port connected to the heat flow.
Dependencies
To use this port, in the parameter group Cone Clutch set for the parameter Friction model meaning Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients.
| Program usage name |
|
#
HA
—
coupling hub
rotational mechanics
Details
Non-directional mechanical port connected to the hub shaft the couplings.
| Program usage name |
|
#
S
—
gearshift lever
translational mechanics
Details
A non-directional mechanical port connected to the gearshift lever.
| Program usage name |
|
#
R
—
coupling ring
rotational mechanics
Details
A non-directional mechanical port connected to the coupling ring.
| Program usage name |
|
#
HB
—
coupling hub
rotational mechanics
Details
Non-directional mechanical port connected to the hub shaft the couplings.
| Program usage name |
|
Output
#
X1
—
position of the gearshift lever of the cam clutch
scalar
Details
The output port of a scalar signal measuring the amount of translational motion of the gearshift lever of the cam clutch.
| Data types |
|
| Complex numbers support |
No |
#
X2
—
the position of the gearshift lever of the conical clutch
scalar
Details
The output port of a scalar signal measuring the amount of translational motion of the gearshift lever of the conical clutch.
| Data types |
|
| Complex numbers support |
No |
Parameters
Cone Clutch
# Kinetic friction coefficient vector — vector of sliding friction coefficients
Details
The vector of kinetic friction coefficient values. All values must be greater than zero. The dimension of the vector must match the dimension of the vector Temperature vector.
Dependencies
To use this parameter, set for the parameter Friction model meaning Temperature-dependent friction coefficients.
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
# Kinetic friction coefficient vector — vector of sliding friction coefficients
Details
The vector of kinetic friction coefficient values. All values must be greater than zero. The dimension of the vector must match the dimension of the vector Relative velocity vector.
Dependencies
To use this parameter, set for the parameter Friction model meaning Velocity-dependent kinetic friction coefficient.
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Cone half angle —
half of the opening angle of the cone
rad | deg | rev | mrad | arcsec | arcmin | gon
Details
Half of the opening angle of the cone .
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
# Static friction coefficient vector — vector of static friction coefficients
Details
A vector of static or peak friction coefficients. The dimension of this vector must match the dimension of the vector Temperature vector. Each value must be greater than the value of the corresponding element in the vector. Kinetic friction coefficient vector.
Dependencies
To use this parameter, set for the parameter Friction model meaning Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients.
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
# Kinetic friction coefficient — coefficient of sliding friction
Details
Coefficient of kinetic or Coulomb friction. The coefficient must be greater than zero.
Dependencies
To use this parameter, set for the parameter Friction model meaning Fixed kinetic friction coefficient.
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Temperature vector —
vector of temperature values
K | degC | degF | degR | deltaK | deltadegC | deltadegF | deltadegR
Details
The vector of temperature values. The values in the vector should increase from left to right. For linear interpolation, specify at least two values for each dimension, and for smooth interpolation, specify at least three.
Dependencies
To use this parameter, set for the parameter Friction model meaning Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
# Static friction coefficient — coefficient of static friction
Details
Static or peak value of the coefficient of friction. The static coefficient of friction must be greater than the kinetic coefficient of friction.
Dependencies
To use this parameter, set for the parameter Friction model meaning Fixed kinetic friction coefficient or Velocity-dependent kinetic friction coefficient.
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Friction coefficient extrapolation method —
the extrapolation method
Linear | Nearest | Error
Details
The method used to extrapolate the reference points in the data table. This method determines the output value when the input value is outside the range specified in the argument list.:
-
Linear— select this value to obtain a curve with continuous first-order derivatives in the extrapolation region and on the boundary with the interpolation region. -
Nearest— Select this value to use an extrapolation that does not rise above the largest value in the data or fall below the smallest value in the data. -
Error— select this value to avoid extrapolation when you want the data to be within the range of the table. If the input signal is outside the range of the table, the simulation stops and outputs an error.
For more information about extrapolation algorithms, see the block page. 1-D Lookup Table.
Dependencies
To use this parameter, set for the parameter Friction model meaning Velocity-dependent kinetic friction coefficient, Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients.
| Values |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
No |
#
Velocity tolerance —
threshold value of relative blocking speed
rad/s | deg/s | rad/min | deg/min | rpm | rps
Details
The relative speed below which the clutch can lock. The surfaces are fixed if the torque is less than the product of the effective radius, the coefficient of static friction and the applied normal force.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Contact surface minimum diameter —
inner diameter
m | um | mm | cm | km | in | ft | yd | mi | nmi
Details
Inner diameter of the cone .
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Relative velocity vector —
vector of relative velocities
rad/s | deg/s | rad/min | deg/min | rpm | rps
Details
A vector of relative velocity values. The values in the vector should increase from left to right. For linear interpolation, specify at least two values for each dimension, and for smooth interpolation, specify at least three.
Dependencies
To use this parameter, set for the parameter Friction model meaning Velocity-dependent kinetic friction coefficient or Temperature and velocity-dependent friction coefficients.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Contact surface maximum diameter —
Outer diameter
m | um | mm | cm | km | in | ft | yd | mi | nmi
Details
Outer diameter of the cone .
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Friction coefficient interpolation method —
the interpolation method
Linear | Smooth
Details
The method used for interpolation between data table reference points:
-
Linear— select this value for the lowest computational cost. -
Smooth— select this value to get a continuous curve with continuous first-order derivatives.
Dependencies
To use this parameter, set for the parameter Friction model meaning Velocity-dependent kinetic friction coefficient, Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients.
| Values |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
No |
#
Friction model —
the friction model
Fixed kinetic friction coefficient | Velocity-dependent kinetic friction coefficient | Temperature-dependent friction coefficients | Temperature and velocity-dependent friction coefficients
Details
Parameterization method for modeling the coefficient of sliding friction. The parameters and default values for this parameter depend on the friction model you select for the block. The following options are possible:
-
Fixed kinetic friction coefficient— a fixed value is set for the sliding friction coefficient. -
Velocity-dependent kinetic friction coefficient— the coefficient of sliding friction is determined by an interpolation table based on the values of the relative angular velocity between the discs. -
Temperature-dependent friction coefficients— the coefficient of sliding friction is determined by an interpolation table based on temperature values. -
Temperature and velocity-dependent friction coefficients— the coefficient of sliding friction is determined by an interpolation table based on the values of temperature and relative angular velocity between the discs.
| Values |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
No |
#
Threshold force —
the threshold value of the normal contact force
N | nN | uN | mN | kN | MN | GN | dyn | lbf | kgf
Details
The threshold value of the force. The block simulates the normal force only when it exceeds the value of the parameter. Threshold force. Otherwise, the friction torque is not transmitted.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
# Kinetic friction coefficient matrix — matrix of sliding friction coefficients
Details
The matrix of kinetic friction coefficient values. All values must be greater than zero. The dimension of the matrix should be (Temperature vector) on (Kinetic friction coefficient vector).
Dependencies
To use this parameter, set for the parameter Friction model meaning Temperature and velocity-dependent friction coefficients.
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
Shift Linkage
# Tooth-tooth friction coefficient — coefficient of kinetic friction when the cams come into contact with each other
Details
The coefficient of kinetic friction in the contact zone between the cams of the ring and the hub. This coefficient characterizes the dissipative force that prevents the gearshift lever from moving due to the contact of the cams with each other when the clutch is turned on and off.
Higher coefficient values correspond to greater energy dissipation when the gearshift lever is moved. The value must be greater than zero.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Fixed kinetic friction coefficient or Velocity-dependent kinetic friction coefficient, and in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic with backlash.
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Cone clutch ring stop stiffness —
rigidity of the annular stop of the conical coupling
N/m | mN/m | kN/m | MN/m | GN/m | kgf/m | lbf/ft | lbf/in
Details
The rigidity of the annular stop on both sides of the conical coupling ring. The model assumes that the ring and the stops behave elastically, and the deformation upon contact is proportional to the applied force and magnitude, the inverse stiffness of the contact.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Static contact speed threshold —
threshold value of static contact speed
m/s | mm/s | cm/s | km/s | m/hr | km/hr | in/s | ft/s | mi/s | ft/min | mi/hr | kn
Details
The speed threshold value below which the ring and hub are either fully on and locked, or completely off and locked.
Dependencies
To use this parameter, in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic modal.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Engagement block stiffness —
the coefficient of rigidity of the engagement lock
N/m | mN/m | kN/m | MN/m | GN/m | kgf/m | lbf/ft | lbf/in
Details
The coefficient of rigidity when locking the engagement.
Dependencies
To use this parameter, in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic modal.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Engagement block damping —
the damping coefficient of the engagement lock
N*s/m | kgf*s/m | lbf*s/ft | lbf*s/in
Details
The damping coefficient when the engagement is blocked.
Dependencies
To use this parameter, in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic modal.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Viscous friction coefficient —
coefficient of viscous friction of the gearshift lever
N*s/m | kgf*s/m | lbf*s/ft | lbf*s/in
Details
The coefficient of viscous friction in the relative translational motion between the hub and the ring. The value of the parameter depends on the condition of the lubricant and the quality of the contacting surfaces. The value of this parameter must be greater than or equal to zero.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Cone clutch ring stop damping —
damping coefficient of the annular stop of the conical coupling
N*s/m | kgf*s/m | lbf*s/ft | lbf*s/in
Details
Damping of translational contact between the ring of the conical coupling and the hub. The amount of damping is inversely proportional to the number of vibrations that occur after contact. The value of this parameter must be greater than zero.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Ring-hub clearance when cone clutch disengaged —
the gap between the ring and the hub in the off state of the conical coupling
m | um | mm | cm | km | in | ft | yd | mi | nmi
Details
The maximum gap between the cams of the ring and the hub along the axis of movement of the gear lever. This gap corresponds to a fully switched-off coupling. The height of the cams and the gap between the ring and the hub in the off state determine the maximum stroke of the gearshift lever. The value of this parameter must be greater than zero.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Shift linkage engaged friction coefficient —
coefficient of friction when switched on
N*s/m | kgf*s/m | lbf*s/ft | lbf*s/in
Details
The coefficient of friction in the gearshift lever when the ring and hub engage. This value represents the friction between the gearshift lever and its support.
Dependencies
To use this parameter, in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic modal.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Ring-hub clearance when dog clutch disengaged —
the gap between the ring and the hub when the cam clutch is switched off
m | um | mm | cm | km | in | ft | yd | mi | nmi
Details
The maximum gap between the cams of the ring and the hub along the axis of movement of the gear lever. This gap corresponds to a fully switched-off coupling. The height of the cams and the gap between the ring and the hub in the off state determine the maximum stroke of the gearshift lever. The value of this parameter must be greater than zero.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Maximum engagement speed —
upper threshold of the switching speed
rad/s | deg/s | rad/min | deg/min | rpm | rps
Details
The relative angular velocity between the ring and the hub, beyond which the clutch cannot be engaged. The value depends on the specific transmission or transmission. Minimizing the value helps to avoid a strong dynamic impact when switching on. The value must be greater than zero.
Dependencies
To use this parameter, set for the parameter Torque transmission model meaning Friction clutch approximation - Suitable for HIL and linearization or Dynamic with backlash.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Tooth overlap to engage —
threshold value of cam overlap for coupling activation
m | um | mm | cm | km | in | ft | yd | mi | nmi
Details
The length of the overlap between the cams of the ring and the hub along the common longitudinal axis. The clutch is activated when the cam overlap exceeds this value. The clutch remains off until the cams of the engaging gears overlap by at least this length. The value must be greater than zero.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Tooth height —
cam height
m | um | mm | cm | km | in | ft | yd | mi | nmi
Details
The distance between the base and the top of the cam. The cams of the ring and the hub have the same height. The height of the cams and the gap between the ring and the hub in the off state determine the maximum stroke of the gearshift lever. The value of this parameter must be greater than zero.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Static contact release force threshold —
threshold value of the decoupling force
N | nN | uN | mN | kN | MN | GN | dyn | lbf | kgf
Details
The threshold value of the force at which the ring and hub can be released and disengaged.
Dependencies
To use this parameter, in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic modal.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Dog clutch ring stop damping —
damping of the cam clutch ring stop
N*s/m | kgf*s/m | lbf*s/ft | lbf*s/in
Details
Damping of the translational contact between the cam clutch ring and the hub. The amount of damping is inversely proportional to the number of vibrations that occur after contact. The value of this parameter must be greater than zero.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Dog clutch ring stop stiffness —
stiffness of the cam clutch ring stop
N/m | mN/m | kN/m | MN/m | GN/m | kgf/m | lbf/ft | lbf/in
Details
The stiffness of the stop on both sides of the cam clutch ring. The model assumes that the ring and the stops behave elastically, and the deformation upon contact is proportional to the applied force and magnitude, the inverse stiffness of the contact. The stiffness value must be set based on the parameter Tooth overlap to engage. Too low a stiffness can cause the deformation to exceed the required overlap and cause false activation. The parameter value must be greater than zero.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Shift linkage disengaged friction coefficient —
coefficient of friction in the off state
N*s/m | kgf*s/m | lbf*s/ft | lbf*s/in
Details
The coefficient of friction in the gearshift lever when the ring and hub are uncoupled. This value represents the friction between the gearshift lever and its support.
Dependencies
To use this parameter, in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic modal.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
Detent
#
Notch width —
the area of shear force
m | um | mm | cm | km | in | ft | yd | mi | nmi
Details
The width of the area where the shear force occurs.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Friction velocity threshold —
threshold value of the friction velocity
m/s | mm/s | cm/s | km/s | m/hr | km/hr | in/s | ft/s | mi/s | ft/min | mi/hr | kn
Details
The relative velocity required to achieve maximum kinetic friction in the retainer. This parameter ensures the continuity of the force when changing the direction of motion, increasing the numerical stability of the simulation. The parameter value must be greater than zero.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Peak force —
maximum shear force
N | nN | uN | mN | kN | MN | GN | dyn | lbf | kgf
Details
The maximum shear force generated inside the retainer.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Viscous friction coefficient —
coefficient of viscous friction of the retainer
N*s/m | kgf*s/m | lbf*s/ft | lbf*s/in
Details
Coefficient of viscous friction on the contact surface of the retainer. The parameter value must be greater than or equal to zero.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
# Friction to peak force ratio — coefficient of kinetic friction
Details
The ratio of the kinetic friction force to the maximum shear force of the lock. This parameter is used to set the kinetic friction force. The parameter value must be greater than or equal to zero.
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
Initial Conditions
#
Cone clutch initial shift linkage position —
the initial position of the gearshift lever of the conical clutch
m | um | mm | cm | km | in | ft | yd | mi | nmi
Details
The initial position of the gearshift lever of the conical clutch. The parameter limitations are shown in the following table.
| Condition of the conical coupling | Parameter Limitation |
|---|---|
Conical coupling initially enabled |
The negative value of the parameter must be greater than the value Ring-hub clearance when cone clutch disengaged |
Conical coupling initially disabled |
The negative value of the parameter must be less than the value Ring-hub clearance when cone clutch disengaged |
Conical coupling initially enabled |
The parameter value must be greater than the value Ring-hub clearance when cone clutch disengaged |
Conical coupling initially disabled |
The parameter value must be less than Ring-hub clearance when cone clutch disengaged |
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Dog clutch initial shift linkage position —
the initial position of the gearshift lever of the cam clutch
m | um | mm | cm | km | in | ft | yd | mi | nmi
Details
The initial position of the gearshift lever of the cam clutch. The parameter limitations are shown in the following table.
| Condition of the cam clutch | Parameter Limitation |
|---|---|
Cam clutch initially enabled |
The negative parameter value must be greater than the sum of the parameter values. Ring-hub clearance when dog clutch disengaged and Tooth overlap to engage |
Cam clutch initially disabled |
The negative parameter value must be less than the sum of the parameter values. Ring-hub clearance when dog clutch disengaged and Tooth overlap to engage |
Cam clutch initially enabled |
The parameter value must be greater than the sum of the parameter values. Ring-hub clearance when dog clutch disengaged and Tooth overlap to engage |
Cam clutch initially disabled |
The parameter value must be less than the sum of the parameter values. Ring-hub clearance when dog clutch disengaged and Tooth overlap to engage |
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Initial dog clutch B ring-hub offset angle —
the initial angle of displacement of the ring relative to the hub of the cam clutch
rad | deg | rev | mrad | arcsec | arcmin | gon
Details
The angle of rotation between the ring and the hub at the zero point in the simulation time. This angle determines the possibility of engagement of the ring and hub cams. The initial displacement angle must satisfy these conditions:
-
If the initial state of the coupling is off, the initial offset angle must be in the range
where — the number of cams of the ring or hub. Both components have the same number of cams.
-
If the initial state of the coupling is on, the initial offset angle must be in the range
where — the angle of the gap between the cams of the ring and the hub.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Fixed kinetic friction coefficient or Velocity-dependent kinetic friction coefficient, and in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic with backlash.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Initial state —
initial condition of the coupling
Cone clutch A and dog clutch A locked | Cone clutch A locked | All clutches unlocked | Cone clutch B locked | Cone clutch B and dog clutch B locked
Details
The condition of the conical and cam couplings at the beginning of the simulation:
-
Cone clutch A and dog clutch A locked— conical coupling and the cam clutch the torque is transmitted between the ring and the hub; -
Cone clutch A locked— conical coupling transmits the torque between the ring and the hub; -
All clutches unlocked— conical and cam couplings transfer zero torque between the ring and the hub; -
Cone clutch B locked— conical coupling transmits the torque between the ring and the hub; -
Cone clutch B and dog clutch B locked— conical coupling and the cam clutch the torque is transmitted between the ring and the hub.
| Values |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
No |
#
Initial dog clutch A ring-hub offset angle —
the initial angle of displacement of the ring relative to the hub of the cam clutch
rad | deg | rev | mrad | arcsec | arcmin | gon
Details
The angle of rotation between the ring and the hub at the zero point in the simulation time. This angle determines the possibility of engagement of the ring and hub cams. The initial displacement angle must satisfy these conditions:
-
If the initial state of the coupling is off, the initial offset angle must be in the range
where — the number of cams of the ring or hub. Both components have the same number of cams.
-
If the initial state of the coupling is on, the initial offset angle must be in the range
where — the angle of the gap between the cams of the ring and the hub.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Fixed kinetic friction coefficient or Velocity-dependent kinetic friction coefficient, and in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic with backlash.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
Thermal Port
#
Initial temperature —
Initial temperature
K | degC | degF | degR | deltaK | deltadegC | deltadegF | deltadegR
Details
The temperature of the component at the beginning of the simulation. The initial temperature changes the efficiency of the component by adjusting the initial engagement or friction losses.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Thermal mass —
heat capacity
J/K | kJ/K
Details
The thermal energy required to change the temperature of a component by one degree. The higher the heat capacity, the more resistant the component is to temperature changes.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
Dog Clutch
#
Torsional stiffness —
torsional stiffness
N*m/rad | mN*m/rad | kN*m/rad | kgf*m/rad | lbf*ft/rad | N*m/deg | mN*m/deg | kN*m/deg | kgf*m/deg | lbf*ft/deg | W*s/rad | HP_DIN/rpm | HP_DIN*s/rad
Details
The coefficient of linear torsional stiffness in the contact zone between the cams of the ring and the hub. This coefficient characterizes the restoring component of the contact force between two pairs of cams. High stiffness values correspond to high contact forces. The value must be greater than zero.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Fixed kinetic friction coefficient or Velocity-dependent kinetic friction coefficient, and in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic with backlash.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Extrapolation method —
the extrapolation method
Linear | Nearest | Error
Details
An extrapolation method for determining the output value when the input value is outside the range specified in the argument list.:
-
Linear— select this value to plot a curve with continuous first-order derivatives in the extrapolation domain and on the boundary with the interpolation domain; -
Nearest— select this value to get an extrapolation that does not go beyond the highest point in the data and does not go beyond the lowest point in the data.; -
Error— select this value to avoid going into extrapolation mode. If the input signal is outside the tabular range, the simulation stops and returns an error.
For more information about extrapolation algorithms, see the block page. 1-D Lookup Table.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients.
| Values |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
No |
# Number of teeth — number of cams rings or hubs
Details
The total number of cams of the ring or hub. Both components have the same number of cams. This value must be greater than or equal to one.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Fixed kinetic friction coefficient or Velocity-dependent kinetic friction coefficient, and in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic with backlash.
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Temperature vector —
vector of temperature values
K | degC | degF | degR | deltaK | deltadegC | deltadegF | deltadegR
Details
The vector of temperature values. The values in the vector should increase from left to right. For linear interpolation, specify at least two values for each dimension, and for smooth interpolation, specify at least three.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Engagement speed threshold —
switching speed threshold value
rad/s | deg/s | rad/min | deg/min | rpm | rps
Details
The minimum rotation speed at which the clutch provides power.
Dependencies
To use this parameter, set for the parameter Torque transmission model meaning Dynamic modal.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Maximum transmitted torque —
maximum transmitted torque
N*m | uN*m | mN*m | kN*m | MN*m | GN*m | kgf*m | lbf*in | lbf*ft
Details
The maximum torque that the clutch can transmit. This value corresponds to a non-slip engagement configuration. If the torque transmitted between the ring and the hub exceeds this value, both components begin to slip relative to each other. This torque determines the limit of static friction in the approximation of a friction clutch.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Fixed kinetic friction coefficient or Velocity-dependent kinetic friction coefficient, and in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Friction clutch approximation - Suitable for HIL and linearization.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Rotational backlash —
backlash during rotation
rad | deg | rev | mrad | arcsec | arcmin | gon
Details
Permissible angular displacement (backlash) between the ring and hub cams when the clutch is engaged. This value must be greater than zero.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Fixed kinetic friction coefficient or Velocity-dependent kinetic friction coefficient, and in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic with backlash.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Clutch teeth mean radius —
the average radius of the clutch cams
m | um | mm | cm | km | in | ft | yd | mi | nmi
Details
The distance from the center of the ring or hub to the corresponding center of the cams. The average cam radius determines the normal contact forces between the ring and hub cams, taking into account the torque transmitted between the two components. This value must be greater than zero.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Maximum transmitted torque vector —
maximum transmitted torque
N*m | uN*m | mN*m | kN*m | MN*m | GN*m | kgf*m | lbf*in | lbf*ft
Details
The maximum torque that the clutch can transmit. The vector of these values corresponds to a configuration with a non-slip engagement. If the torque transmitted between the ring and the hub exceeds this value, both components begin to slip relative to each other. The vector must have the same number of elements as Temperature vector.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |
#
Torque transmission model —
the model of torque transmission
Friction clutch approximation - Suitable for HIL and linearization | Dynamic with backlash | Dynamic modal
Details
A method for modeling the operation of a cam clutch:
-
Friction clutch approximation - Suitable for HIL and linearization— composite block implementation Fundamental Friction Clutch medium and high precision. This setting supports thermal modeling. The gearshift lever can be controlled either via a scalar signal or via a non-directional port S. -
Dynamic with backlash— A high-precision clutch actuation model that takes into account phenomena such as backlash, torsional compliance, and contact forces between the ring and hub cams. -
Dynamic modal— a coupling activation model at the system level that takes into account the impact of engagement lock due to speed differences.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Fixed kinetic friction coefficient or Velocity-dependent kinetic friction coefficient.
| Values |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
No |
#
Interpolation method —
the interpolation method
Linear | Smooth
Details
An interpolation method for approximating the output value when the input value is between two consecutive grid points:
-
Linear— Select this value to achieve the best performance. -
Smooth— select this value to plot a continuous curve with continuous first-order derivatives.
For more information about interpolation algorithms, see the block page. 1-D Lookup Table.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Temperature-dependent friction coefficients or Temperature and velocity-dependent friction coefficients.
| Values |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
No |
#
Torsional damping —
torsion damping
N*m*s/rad | mN*m*s/rad | kN*m*s/rad | kgf*m*s/rad | lbf*ft*s/rad
Details
The coefficient of linear damping during torsion in the contact zone between the cams of the ring and the hub. This coefficient characterizes the dissipative component of the contact force between two pairs of cams. Higher damping values correspond to greater energy dissipation upon contact. The value must be greater than zero.
Dependencies
To use this parameter, in the parameter group Cone Clutch set for the parameter Friction model meaning Fixed kinetic friction coefficient or Velocity-dependent kinetic friction coefficient, and in the parameter group Dog Clutch set for the parameter Torque transmission model meaning Dynamic with backlash.
| Units |
|
| Default value |
|
| Program usage name |
|
| Evaluatable |
Yes |