RITM-CAN TX
Issuing CAN messages.
blockType: SubSystem
|
Path in the library: |
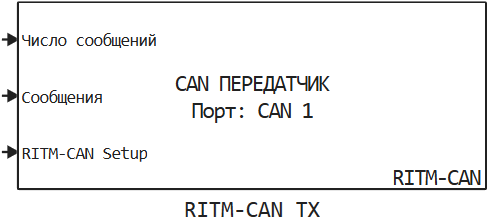
Description
| To work with the block, install/update the support package RITM blocks. |
Block RITM-CAN TX it is used for issuing CAN messages.
Ports
Input
#
Amount
—
number of CAN messages to transmit from the Messages input array
scalar
Details
Specifies the number of messages to transmit from the Messages input array at the current simulation step.
The block transmits the first elements of the Messages array. The value of must not exceed the input array length or the value of the parameter Максимальное число сообщений:. When , no messages are transmitted.
| Data types |
|
| Complex numbers support |
No |
#
Messages
—
array of CAN messages to transmit
bus
Details
Input array of messages of type CAN_MESSAGE_BUS to transmit to the CAN network. Each element is a CAN message bus (ID, format/remote flags, etc., length, and data bytes).
| Data types |
|
| Complex numbers support |
No |
#
Setup
—
handle of the configured CAN interface
scalar
Details
The input port accepts the handle of the CAN interface configured by RITM-CAN Setup. Connect this input to the RITM-CAN RX/TX output of the corresponding RITM-CAN Setup block that configures the required physical port.
| Data types |
|
| Complex numbers support |
No |
Parameters
Параметры:
#
Интерфейс CAN: —
CAN port for message transmission
CAN 1 | CAN 2 | CAN 3 | CAN 4 | CAN 5 | CAN 6 | CAN 7 | CAN 8
Details
The port numbers are indicated on the case of the KPM "RITM".
| Values |
|
| Default value |
|
| Program usage name |
|
| Tunable |
No |
| Evaluatable |
Yes |
# Максимальное число сообщений: — maximum possible number of messages
Details
The maximum possible value for the input port is the Number of messages and the length of the Message vector.
| Default value |
|
| Program usage name |
|
| Tunable |
No |
| Evaluatable |
Yes |
# Шаг расчёта, с: — calculation step in seconds for sending CAN messages from a real-time application
Details
| Default value |
|
| Program usage name |
|
| Tunable |
No |
| Evaluatable |
Yes |