RITM-CANFD GetState
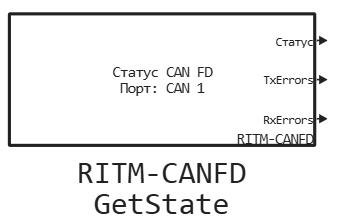
Getting the status of the CAN FD interface and error counters.
blockType: SubSystem
|
Path in the library: |
Description
| To work with the block, install/update the support package RITM blocks. |
Block RITM-CANFD GetState polls the status of the selected interface and outputs transmission and reception error counters. The block does not require connection to the service descriptor RITM-CANFD Setup: The interface number is selected in its parameters.
Ports
Output
#
Status
—
current status of the port
the tire
Details
The bus contains six logic signals. Meaning 1 means that the corresponding state is active.:
-
ACTIVE— the controller is in the active state; -
WARNING— The controller is in a warning state due to previously encountered errors.; -
PASSIVE— the controller has switched to a passive state; -
BUS_OFF— the controller is disconnected from the exchange due to errors; -
STOPPED— the controller is stopped; -
SLEEPING— The controller is in sleep mode.
At any given time, one of the listed signals is active.
| Data types |
|
| Complex numbers support |
No |
#
TxErrors
—
number of transmission errors
scalar
Details
The current value of the CAN controller transmission error counter.
| Data types |
|
| Complex numbers support |
No |
#
RxErrors
—
number of reception errors
scalar
Details
The current value of the CAN controller reception error counter.
| Data types |
|
| Complex numbers support |
No |
Parameters
Main group
#
Интерфейс CAN: —
the port being polled
CAN 1 | CAN 2 | CAN 3 | CAN 4 | CAN 5 | CAN 6 | CAN 7 | CAN 8
Details
| Values |
|
| Default value |
|
| Program usage name |
|
| Tunable |
No |
| Evaluatable |
Yes |
# Шаг расчёта, с: — status survey period
Details
Sets the block calculation step in seconds. Meaning −1 means an inherited step.
| Default value |
|
| Program usage name |
|
| Tunable |
No |
| Evaluatable |
Yes |