Modeling and analysis of the operation of an asynchronous electric drive with scalar control according to the laws of , and
The example is devoted to modeling and analyzing the operation of an asynchronous electric drive with scalar control according to three laws: U/f with voltage drop compensation (IR and IZ), and . Based on the simulation in Engee, the features of each control law are demonstrated: the behavior of rotor speed and torque during acceleration, steady-state, and load build-up. The results are relevant for developers of control systems for electric drives of pumps, fans, conveyors and other mechanisms with different load characteristics.
Introduction
Scalar asynchronous motor control (AD) is one of the most common methods of speed control in industrial electric drives. Its principle is based on maintaining a preset ratio between the amplitude of the stator voltage and the power supply frequency, which allows you to control the flow in the machine without a rotor position sensor. The method became widespread in the 1970s and 1980s with the advent of affordable voltage inverters based on thyristors and transistors, and today it is implemented in almost all serial frequency converters.
Depending on the nature of the load, different scalar control laws are applied.:
-
(linear law) — ensures the consistency of the magnetic flux over the entire frequency range. It is used for drives with a constant load moment: conveyors, hoists, extruders. Additional IR and IZ compensations allow the flow to be maintained at low speeds when the voltage drop across the active resistance of the stator becomes comparable to the EMF of the machine.
-
(quadratic law) — maintains the constant ratio of voltage to the square of frequency. It is used for fan loads, pumps and blowers, where the moment of resistance is proportional to the square of the speed.
-
(law of constancy of the scattering flux) — provides a softer voltage rise with frequency than the linear law. It is used for mechanisms with reduced requirements for the initial moment.
Scalar control is inferior to vector control in terms of dynamic characteristics, but it is easy to implement, does not require a speed sensor, and is well suited for tasks with smooth load changes.
The example model
Model scalar_control_im.engee The one considered in this example is recreated by analogy scalar_control_im.slx[1].
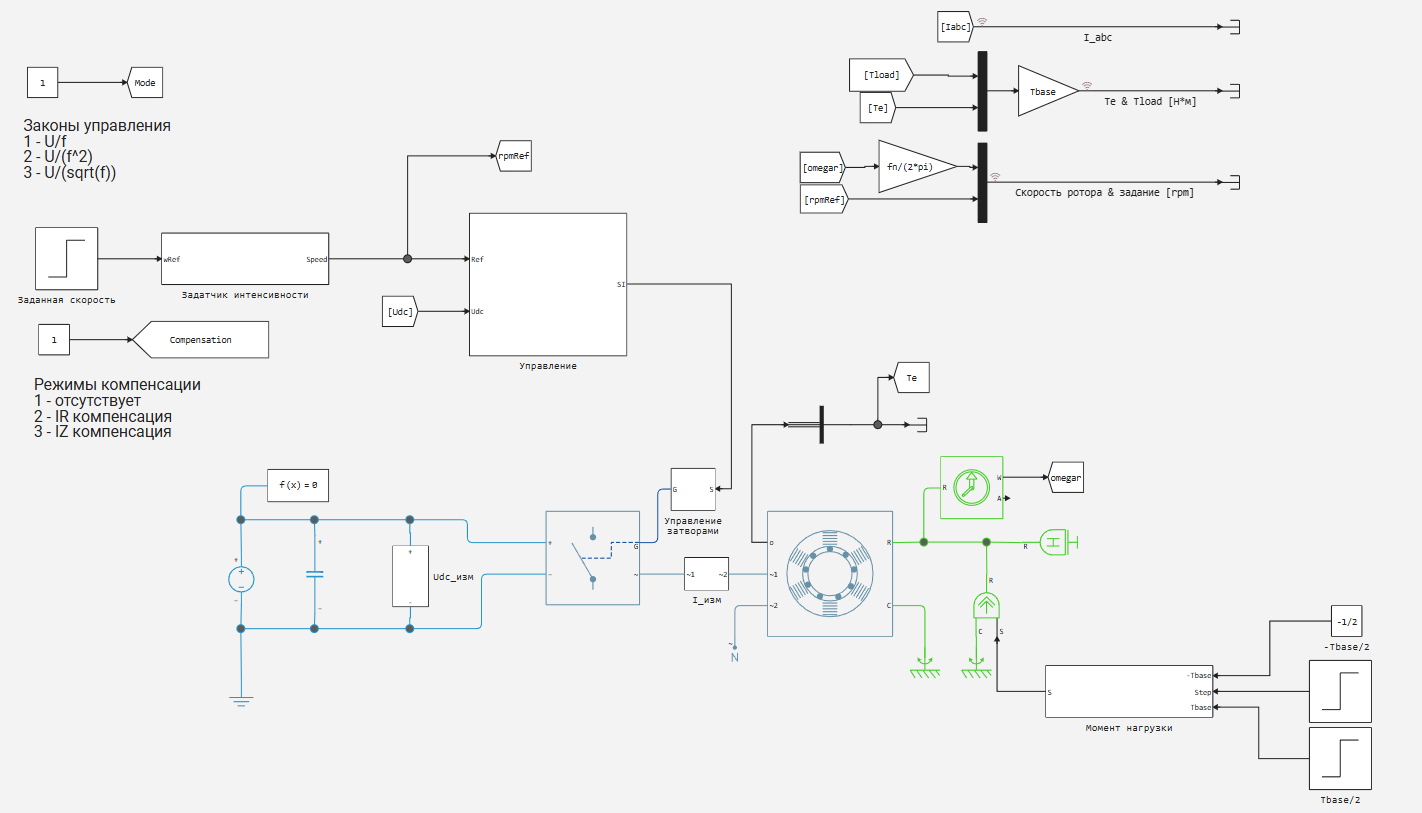
The model consists of a power unit, a control unit, and measurement units. The choice of the control law is set by the parameter Mode (1 — , 2 — , 3 — ), compensation mode is a parameter Compensation (1 — without compensation, 2 — IR-compensation, 3 — IZ-compensation). Thus, one model covers all the studied modes without changing the circuit structure.
The power unit consists of the following elements:
-
DC link constant voltage source with voltage measurement.
-
A DC link capacitor.
-
Three-phase bridge voltage inverter on ideal semiconductor switches, controlled by gate signals.
-
A three-phase stator current measuring unit with three ammeters, which generates a data array.
-
Asynchronous motor with the replacement circuit parameters shown in Table 1.
-
Rotor angular velocity sensor.
-
A block that generates a stepwise moment of resistance.
Engine parameters are shown in Table 1.
|
Parameter |
Designation |
Value |
|
Rated power |
|
164 kW |
|
Rated voltage (interfacial) |
|
380 V |
|
Rated frequency |
|
50 Hz |
|
Number of pairs of poles |
|
2 |
|
Active resistance of the stator |
|
0.0122 Ohms |
|
Active resistance of the rotor |
|
0.0099 Ohms |
|
Inductive resistance of stator scattering |
|
0.0591 Ohms |
|
Inductive resistance of the rotor scattering |
|
0.0591 Ohms |
|
Stator scattering inductance |
|
0.188 MH |
|
Magnetization resistance |
|
2.39 Ohms |
|
The inertia constant |
|
0.2734 s |
|
Coefficient of viscous friction |
|
0.0106 O.E. |
The load is generated by the block Момент нагрузки: at the time specified by the signal Step, the moment switches between values and (braking). This reproduces the start-up, steady-state mode, and load surge/reset.
Intensity setter
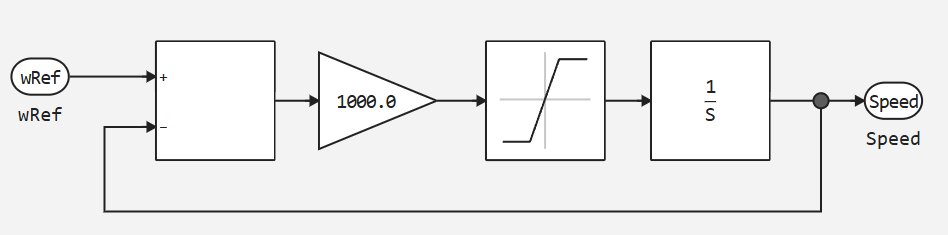
The intensity sensor is implemented as a first-order aperiodic link with a limited rate of increase: the difference between the target and the current output value is multiplied by a factor of 1000, limited by the derivative and integrated by the integrator unit. Feedback on the output closes the circuit, providing linear acceleration at a speed of:
Output signal Speed enters the control unit as the current speed setting in rpm (rpmRef).
Description of the operating principle of the control algorithm
The general structure of the "Management" block
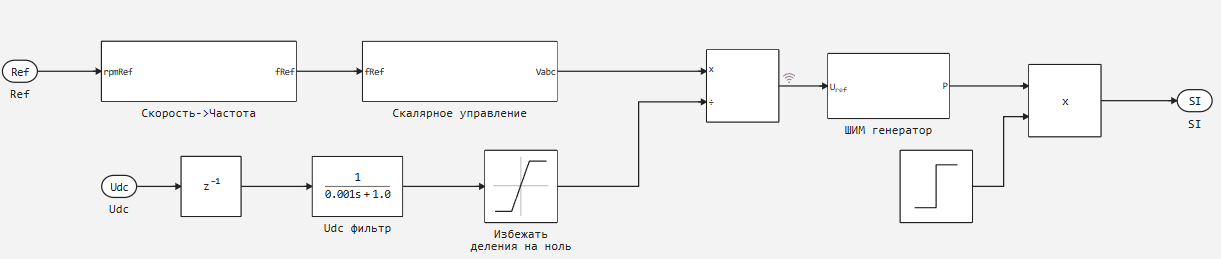
Block Управление accepts the current speed setting as input Ref (rpm) and the measured DC link voltage Udc. Signal processing is performed in the following sequence:
-
Speed → Frequency (
Скорость->Частота): setting the speedrpmRefrecalculated to a preset electrical frequency (Hz). -
Scalar control: the unit generates preset phase voltages in accordance with the chosen law and compensation regime.
-
Normalization by : vector divided by the filtered value (with a filter and limiter to protect against division by zero), converting voltages into relative units of modulation.
-
PWM generator: normalized signal it is supplied to a PWM generator with a switching frequency =2 kHz, forming a three-phase set of control signals for the gates of the inverter.
-
Resolution signal: step signal
StepEnables the operation of the PWM generator by multiplying its output signal by 0 or 1.
Block output signal Управление — vector SI, containing six control signals of the inverter gates.
Scalar Control unit
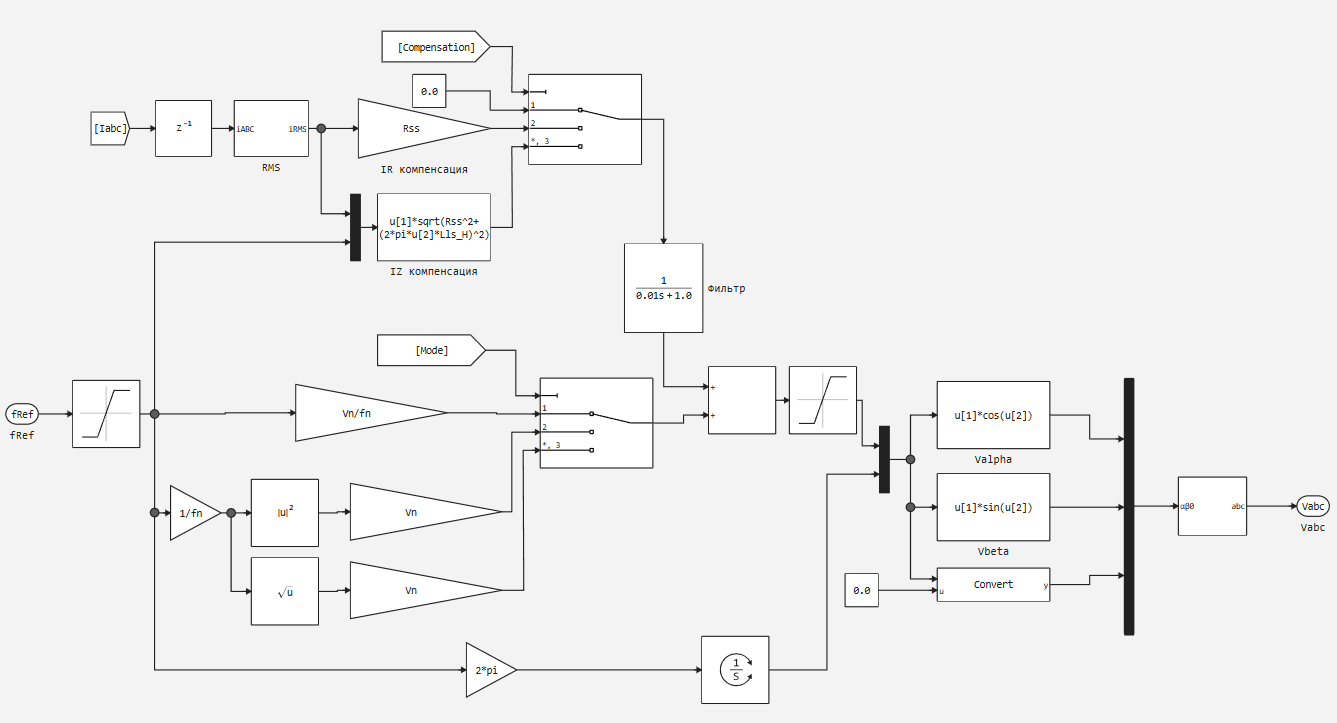
The scalar control unit is the core of the algorithm. A preset frequency is received at its input , stator currents and mode selection signals Mode and Compensation.
Frequency conversion to preset voltage
Based on three variants of the set voltage are formed:
Law 1 — (linear):
Relationship It is kept constant, which ensures the constancy of the main magnetic flux in the entire range of regulation.
Law 2 — (quadratic):
The voltage increases in proportion to the square of the frequency. The magnetic flux decreases linearly with increasing frequency.: , which corresponds to the fan load characteristic .
Law 3 — (the law of constancy of the scattering flux):
The voltage increases proportionally to the root of the frequency. The flow decreases with frequency more slowly than with the quadratic law.
The choice between the three laws is made by the multiplexer on the signal Mode.
Voltage drop compensation
At low speeds (small ) set voltage calculated according to any of the laws, it turns out to be small, and the voltage drop across the active resistance of the stator it begins to significantly reduce the EMF of the machine and the magnetic flux. Two modes are implemented to compensate for this effect.:
IR compensation (Compensation = 2):
where — the effective value of the stator current, calculated from (block RMS with a delay of z−1). The compensation additive is proportional to the active resistance of the stator and the load current, compensating for the active voltage drop.
IZ-compensation (Compensation = 3):
The total voltage drop across the total resistance of the stator is compensated. , including the inductive scattering component. This ensures more precise flow maintenance, especially at medium speeds where the reactive component is already significant.
Both compensation options apply only to the law (Mode = 1). For the laws and compensation is not used. The selected compensation value is added to and passes through a low-pass filter to eliminate high-frequency current ripples in the compensation circuit.
The final set voltage after compensation is limited in amplitude.
Formation of three-phase voltages
From a given frequency The voltage angle is calculated by integration:
Set voltage and the angle They are used to construct a three-phase voltage vector in a coordinate system. :
Then the vector (, , ) is converted from the coordinate system into a three-phase coordinate system by block Преобразование αβ0 в abc:
The resulting vector it goes to the output of the scalar control unit and then to the normalization and PWM generator.
The Shutter Control unit
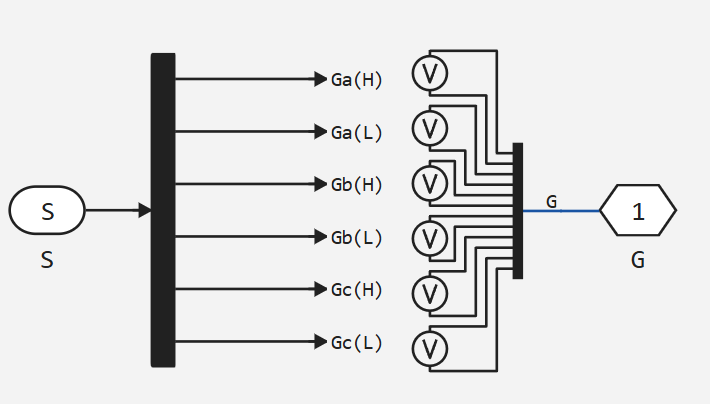
Block Управление затворами receives a vector of signals S and generates six control signals of the inverter gates: Ga(H), Ga(L), Gb(H), Gb(L), Gc(H), Gc(L) — a pair for each shoulder of the bridge (upper and lower keys). The signals of the upper and lower keys of the same arm are complementary, taking into account dead time. Output signal G it is transmitted to the power circuit of the inverter.
The "Load moment" block
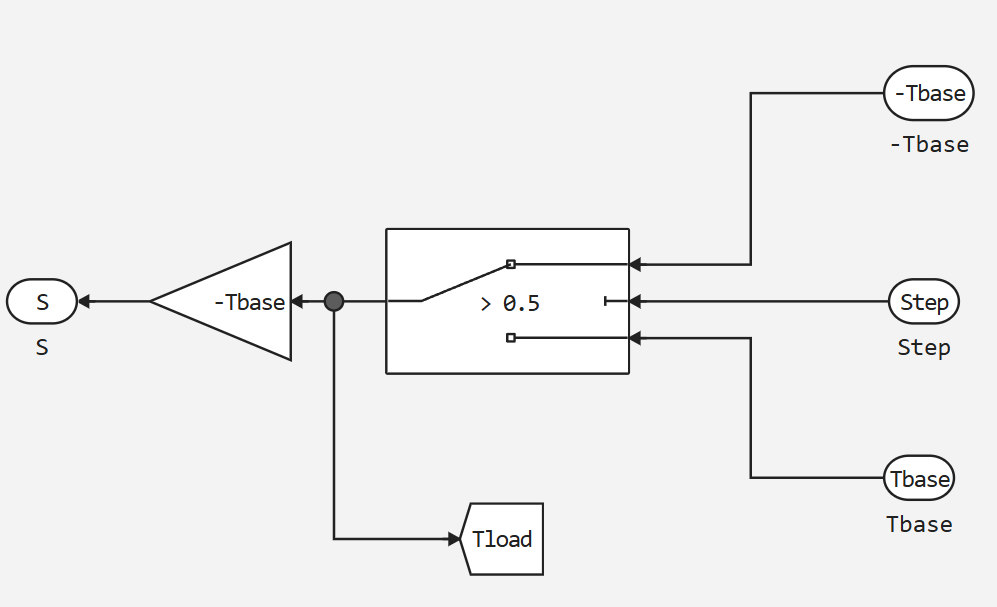
The block generates the load moment acting on the motor shaft. The switch selects between the values and depending on the signal Step (switching threshold 0.5). The output torque is scaled by the coefficient −Tbase (the minus sign is the load torque directed against rotation). The signal at the same time, it is displayed in the model space for display on the graph.
Simulation
The simulation is performed under the following scenario:
-
At the moment t = 0, the intensity sensor starts accelerating the engine to = 800 rpm with constant acceleration for 1.0 s.
-
When the set speed is reached, the engine operates in steady state without load.
-
At a given time (
Step) The rated load torque is applied , after which the load is reset or the sign changes.
The scenario is repeated for each of the three control laws (Mode = 1, 2, 3). Compensation modes (Compensation = 1, 2, 3) relevant only for Mode = 1.
Simulation Parameters:
|
Parameter |
Value |
|
Basic sampling step |
5 microseconds |
|
Switching frequency |
2 kHz |
|
Set speed |
800 rpm |
|
Acceleration time |
1.0 s |
The next code cell will start the simulation:
model_name = "induction_motor_scalar"
model_path = "$(@__DIR__)/$model_name.engee"
engee.load(model_path) |> engee.run; # uploaded and executed the model
engee.close(engee.gcm(), force=true) # the model was closed
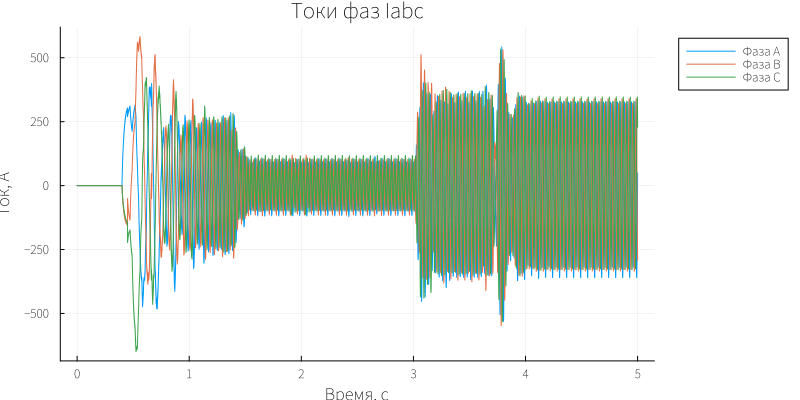
Next, we will plot the instantaneous phase currents.:
gr(size=(800, 400))
I = WorkspaceArrays.plot_wa(WorkspaceArray{Vector{Float64}}("$model_name/I_abc"))
xlabel!(I, "Time, from")
ylabel!(I, "Current, A")
title!(I, "Iabc Phase Currents")

I[1][1][:label] = "Фаза A"
I[1][2][:label] = "Фаза B"
I[1][3][:label] = "Фаза C"

plot!(I, legend=:outertopright)
# I
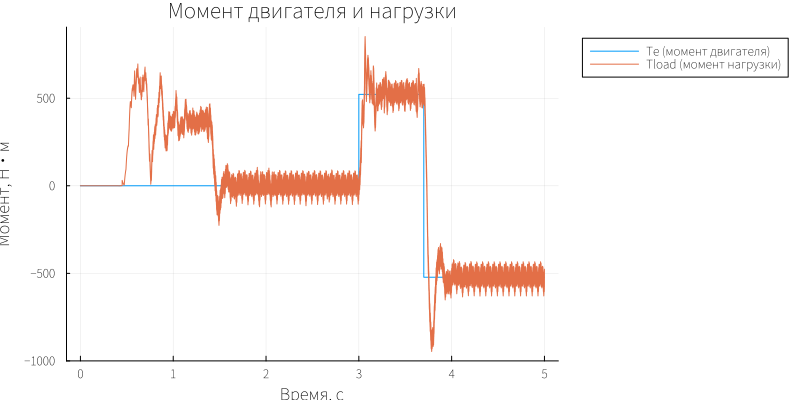
Graphs of load moment and engine moment:
T = WorkspaceArrays.plot_wa(WorkspaceArray{Vector{Float64}}("$model_name/Te & Tload [Н*м]"))
xlabel!(T, "Time, from")
ylabel!(T, "The moment, N·m")
title!(T, "Motor and load torque")

T[1][1][:label] = "Te (момент двигателя)"
T[1][2][:label] = "Tload (момент нагрузки)"

plot!(T, legend=:outertopright)
# T
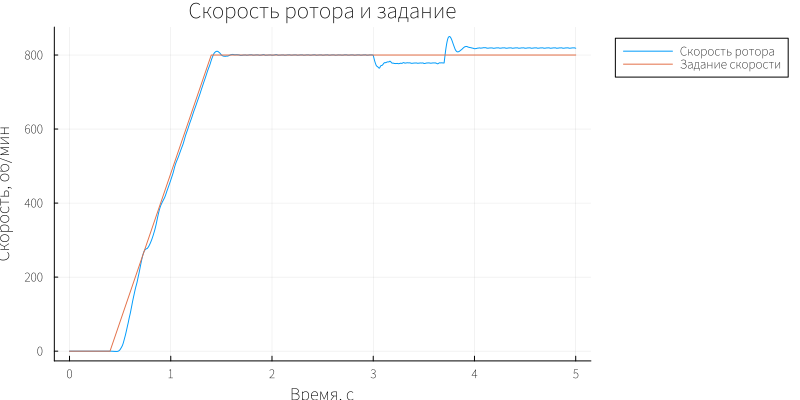
Graphs of the set and actual angular velocity:
w = WorkspaceArrays.plot_wa(WorkspaceArray{Vector{Float64}}("$model_name/Скорость ротора & задание [rpm]"))
xlabel!(w, "Time, from")
ylabel!(w, "Скорость, об/мин")
title!(w, "Rotor speed and setting")

w[1][1][:label] = "Скорость ротора"
w[1][2][:label] = "Задание скорости"

plot!(w, legend=:outertopright)
# w
During acceleration, the electromagnetic torque of the engine (orange curve) reaches values of about 650 Nm, after which it decreases to zero as it reaches a steady speed. In the range t≈1.5–3.0 s, the engine is idling — the torque is close to zero. At the moment t ≈ 3.0 s, a load moment is applied = (blue curve): Te takes a value of about 522 Nm. At t ≈ 3.7 s, the load changes sign to , the electromagnetic moment becomes negative at -522 Nm . Throughout the simulation, ripples of a moment with a switching frequency characteristic of a PWM inverter are observed.
The stator currents (phases a, b, and c — blue, orange, and yellow curves) reach an amplitude of about 560 A during acceleration, which corresponds to the starting mode. In steady-state idle mode, the amplitude decreases to about270 A. After loading at t ≈ 3.0 s, the currents increase to 450 A with characteristic PWM ripples. When the load sign changes in t≈3.7 s, the amplitude of the currents increases to 540 A.
Rotor speed (orange curve) follows the assignment rpmRef (blue curve) in accordance with the characteristic of the intensity sensor: linear acceleration is completed by t≈1.5 s, after which the speed is set at the target level of 800 rpm. When the load drops to t ≈ 3.0 s, the speed drops to 780 rpm. When the load sign changes at t ≈ 3.7 s, a similar short-term deviation is observed. The discrepancy between the target and the actual speed is a consequence of open scalar control — sliding is not compensated by the speed controller.
Conclusion
The example simulates the operation of an asynchronous electric drive with scalar control according to the law in the Engee environment, which confirmed the operability of the open control system during acceleration, steady state, and load surge. It is shown that the linear law It provides stable acceleration of the 164 kW motor to a preset speed of 800 rpm with a limited starting current, however, due to the lack of speed feedback, the actual rotor speed in steady state lags behind the set value of the slip. The simulation results confirm that scalar control provides acceptable dynamic characteristics for mechanisms that do not place high demands on speed accuracy, such as conveyors, pumps, and fans. The IR and IZ compensation modes implemented in the model make it possible to improve the characteristics of the drive in the low-speed range by compensating for the voltage drop across the stator resistance, which is especially important during heavy start-up. The model can serve as a basis for a comparative analysis of management laws. , , as well as a starting point in the transition to more complex algorithms — vector and direct torque control.
Used sources
- Asynchronous Machine Scalar Control — MathWorks Documentation
- Anuchin A. S. Control systems of electric drives : textbook for universities. Moscow : MEI Publishing House, 2015. 371 p. ISBN 978-5-383-00918-5.